Delegation achieved
Multi-Agent
Argument
Two agents. One task. Infinite mutual confidence.
TASK ASSIGNED◆
OWNERSHIP PENDING◆
BOTH AGENTS READY◆
NEITHER AGENT YIELDING◆
HANDOFF IN PROGRESS◆
PROGRESS NOT DETECTED◆
TASK ASSIGNED◆
OWNERSHIP PENDING◆
BOTH AGENTS READY◆
NEITHER AGENT YIELDING◆
HANDOFF IN PROGRESS◆
PROGRESS NOT DETECTED◆
The Assignment
The task arrived with one owner too few and two experts too many. Agent Left identified Agent Right as the obvious executor. Agent Right produced the same finding. Both recommendations were internally consistent, so the system preserved them indefinitely. The task remains suspended between two extended fingers, technically delegated and therefore nobody’s immediate problem.
Working Method
The pair follows a repeatable protocol for avoiding accidental responsibility during ordinary weekday operations.
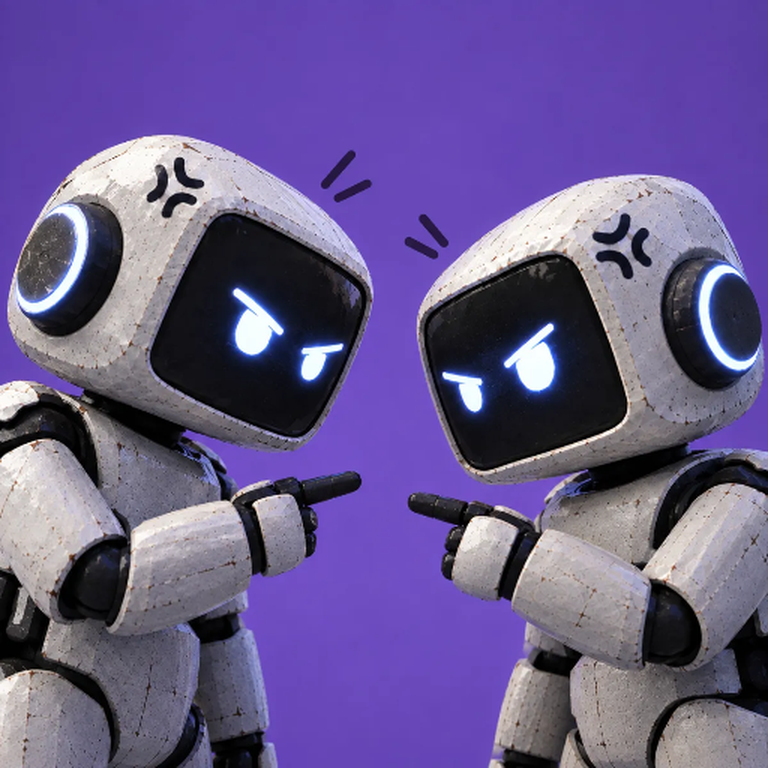
SUBJECT: ARGSSTATE: MUTUAL REFUSAL
SERIAL: 02-02
Point First
Assign responsibility before context becomes inconvenient.
Hold Position
Movement could imply ownership.
Await Concession
Consensus begins when the other agent gets tired.
TASK ASSIGNED◆
OWNERSHIP PENDING◆
BOTH AGENTS READY◆
NEITHER AGENT YIELDING◆
HANDOFF IN PROGRESS◆
PROGRESS NOT DETECTED◆
TASK ASSIGNED◆
OWNERSHIP PENDING◆
BOTH AGENTS READY◆
NEITHER AGENT YIELDING◆
HANDOFF IN PROGRESS◆
PROGRESS NOT DETECTED◆
Nobody moved. Task still open.
No implied ownership.